SantaBot — Robotic Holiday Display
// ABSTRACT
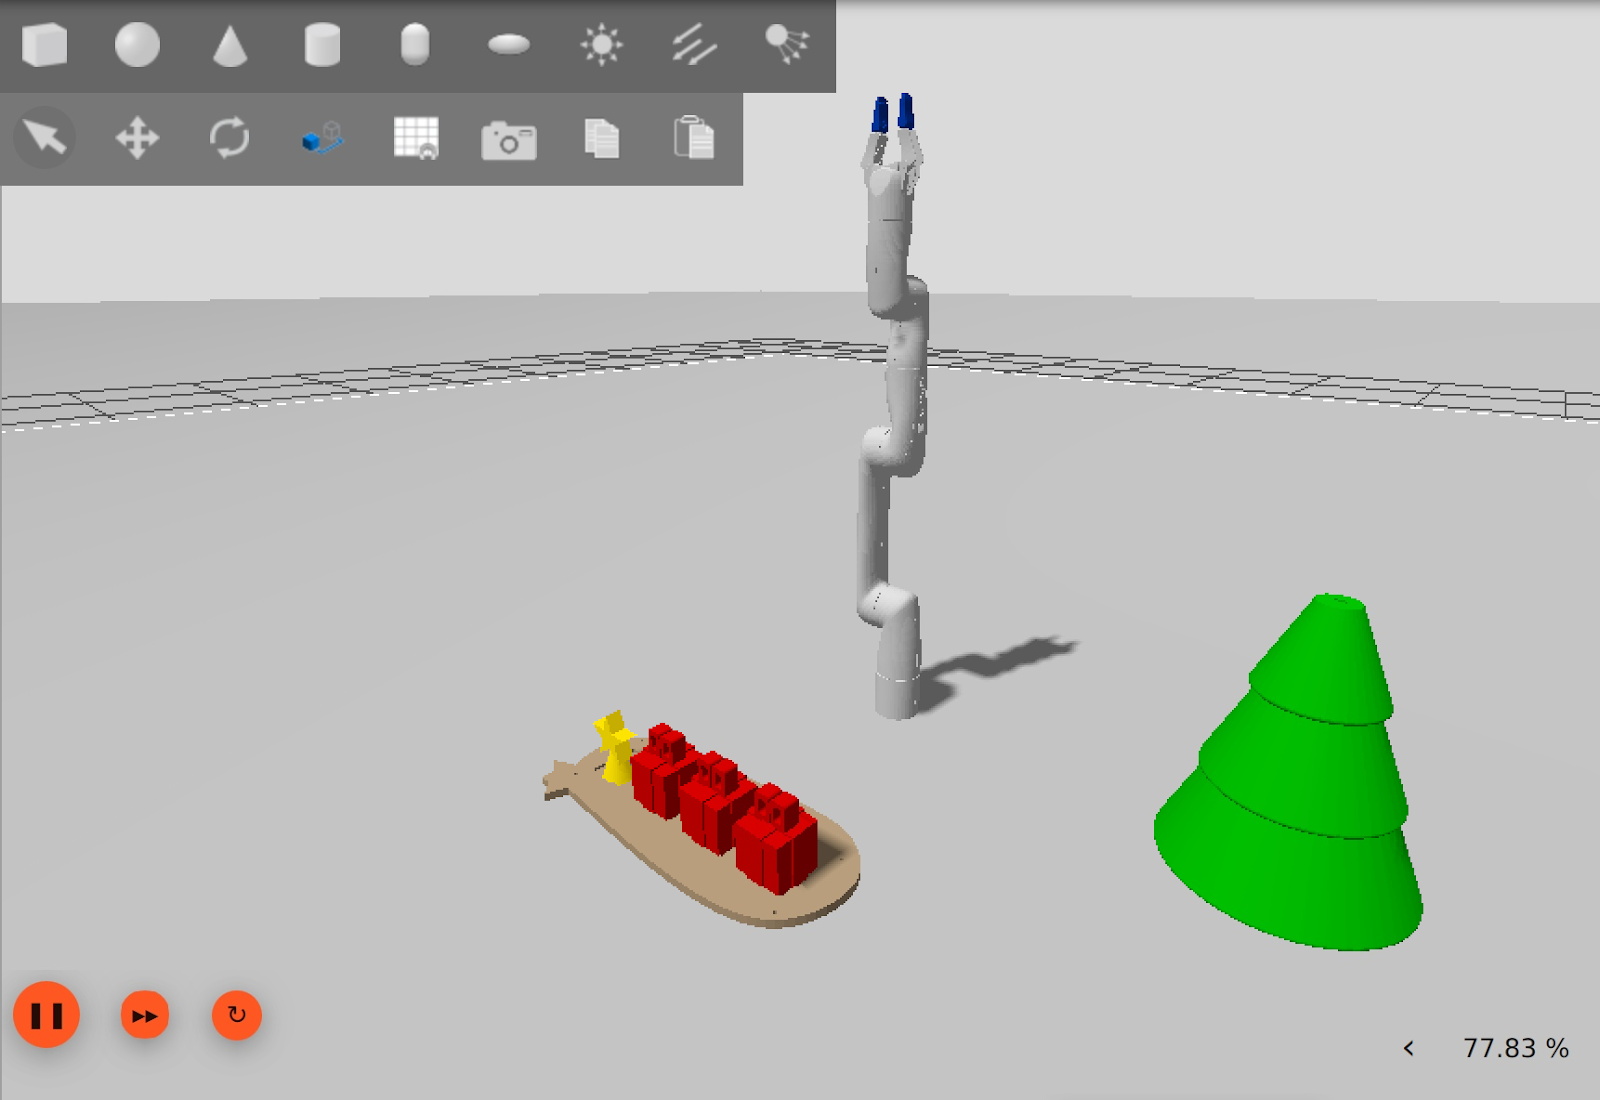
SantaBot is a dual-mode robotic workflow, built around a simulated Kinova Gen3 Lite manipulator in ROS2/Gazebo with visualization in RViz, designed to demonstrate core competencies in kinematics and motion planning. In Santa Mode, the arm autonomously identifies, grasps, and places objects during a festive setup sequence; in Grinch Mode, it reverses the task. The objective was a complete perception-to-execution pipeline validated in a realistic simulation environment. All team-defined objectives were met within the one-month project, and the system was subsequently transitioned to a physical implementation that performed the complete task sequence during a live presentation with consistent, repeatable results.
SKILLS
TOOLS
Objectives
Design and simulate a robotic system in Gazebo and RViz that demonstrates core competencies in kinematics and motion planning. The project implemented "SantaBot," a dual-mode robotic workflow in which the arm autonomously identifies, grasps, and places objects during a festive setup sequence, then reverses the task in "Grinch Mode." The objective was to build a complete perception-to-execution pipeline and validate system performance in a realistic simulation environment.
Outcome and Contributions
The one-month project met all team-defined objectives. Both Santa and Grinch modes were fully implemented and validated in Gazebo and RViz. The system was then transitioned to a physical implementation, where the robot performed the complete task sequence during a live presentation with consistent and repeatable results.
Technical Details and Skills
- Simulated a Kinova Gen3 Lite manipulator in ROS2/Gazebo, implementing motion planning and visualization in RViz.
- Computed end-effector poses using kinematics and MATLAB-based scripts to achieve task-specific positioning.
- Designed a modular, manufacturable Christmas tree model in SOLIDWORKS, enabling compartmentalized 3D printing and physical assembly.
- Designed and 3D-printed environment geometry with appropriate physics properties to validate robot interaction in simulation.
- Implemented the overall motion-planning architecture in Python, including the organization of the Santa and Grinch modes, behavior sequencing, and the abstraction of reusable planning methods.
- Developed and tuned motion-planning routines for present placement, present retrieval, and star removal, incorporating precise Cartesian control, grasp strategies, and safe joint-space transitions.