Maglev PID Controller
// ABSTRACT
For ME 344: Control Systems, a team of three designed a PID controller to operate a magnetic levitation (Maglev) system that levitates a magnetic ball. The system was required to respond to step, sine, square, and random inputs without destabilizing, and to be easily tested and operated through an accessible front panel. The electromechanical system was modeled in MATLAB to establish the required constants, which informed the controller design. The delivered LabVIEW controller responded effectively to inputs at frequencies up to 60 Hz and amplitudes up to 0.25 cm, the most dynamic controller in the class.
SKILLS
TOOLS
Objectives
For ME 344: Control Systems, my team of three was tasked with creating a PID controller to operate a Maglev system that levitates a magnetic ball. As part of the design challenge, the system was required to respond to step, sine, square, and random inputs without destabilization. The program was also required to be easily tested and operated through an accessible front panel.
Outcome and Contributions
The team delivered a LabVIEW PID controller that responded effectively to inputs at frequencies up to 60 Hz and amplitudes up to 0.25 cm, the most dynamic controller in the class. The electromechanical system was first modeled in MATLAB to establish the necessary constants, which were then used to design the PID controller.
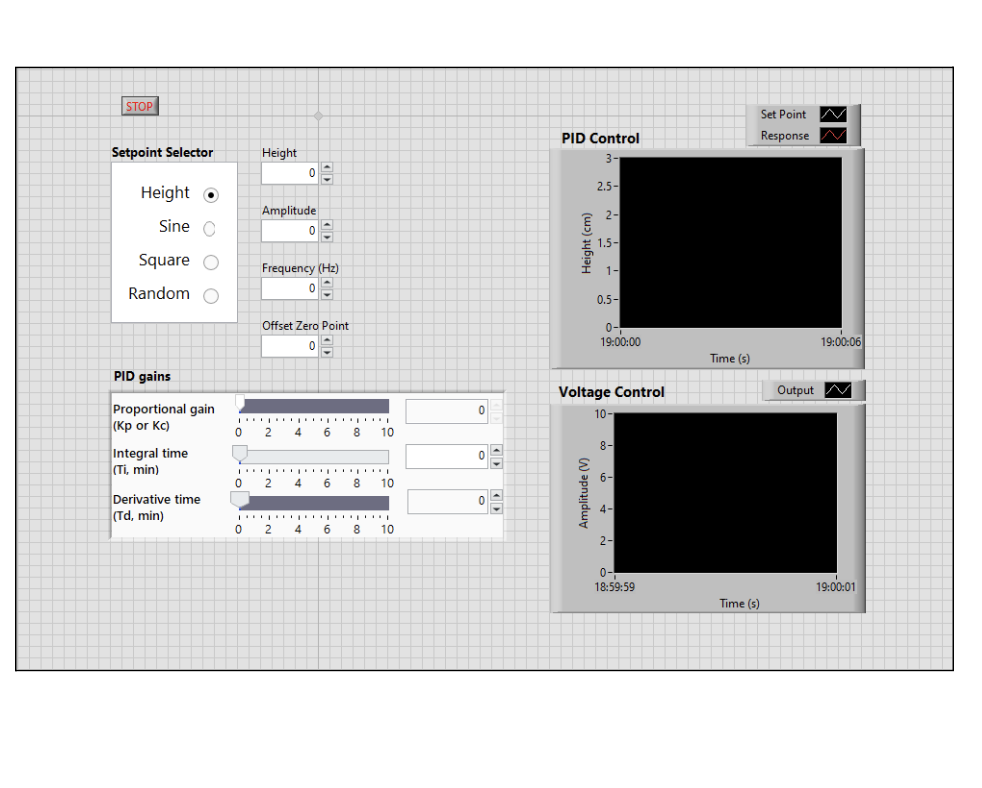
LabVIEW front panel.
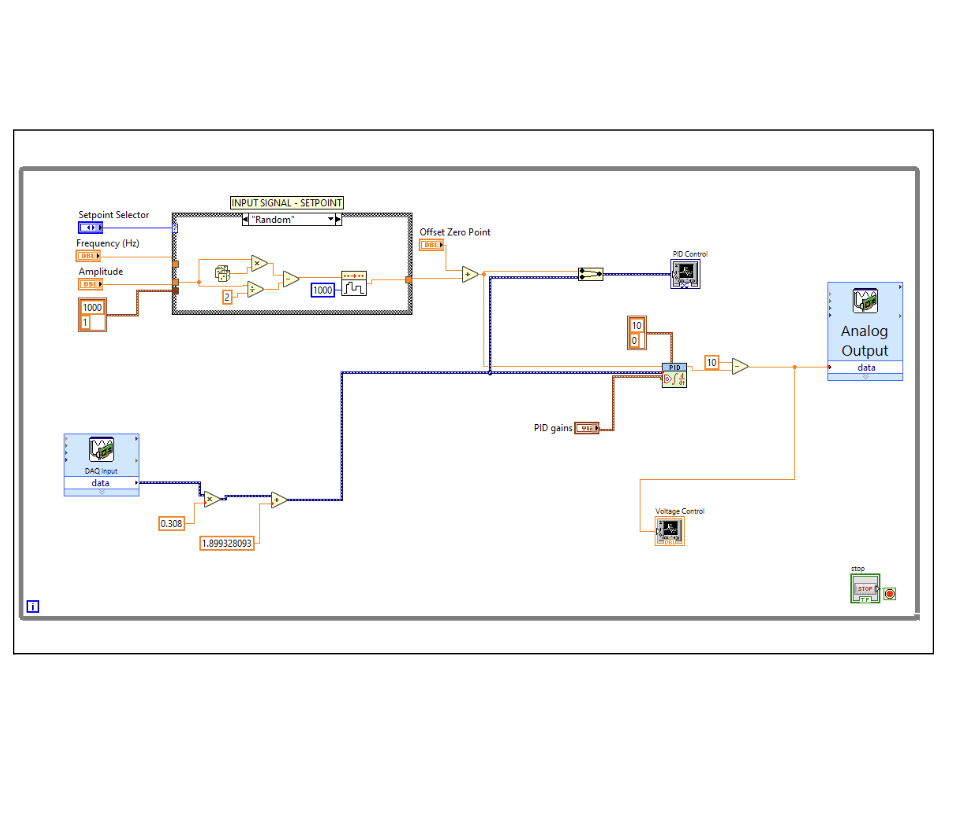
LabVIEW block diagram.
Technical Details and Skills
- Collaborated with teammates to determine appropriate response criteria and derive the governing equations of motion.
- Modeled the electromechanical system in MATLAB and evaluated its governing relations to determine the necessary constants and assess system stability using SISOtool.
- Designed and iteratively tuned the PID controller in LabVIEW, achieving the most robust sinusoidal and random input response in the class.
- Developed a user-friendly front panel for real-time control and visualization.